Bio-Inspired Crutch Robot
— Robotics · Mechanical Design · Dynamic Modeling · Experimentation —
Fall 2024
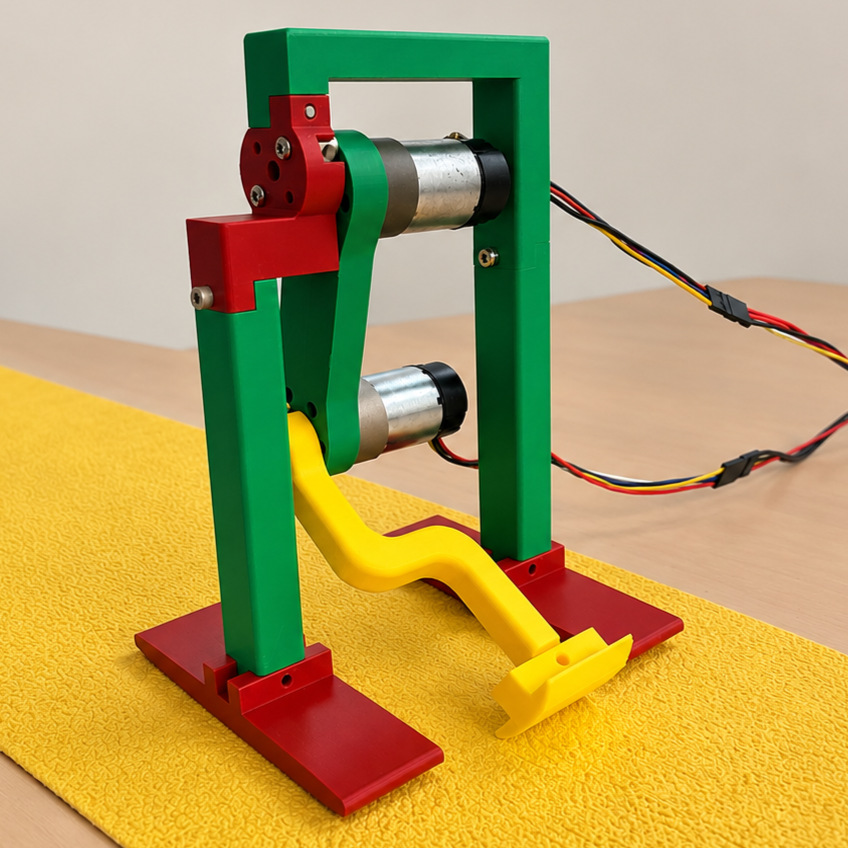
Final crutch-inspired robotic system
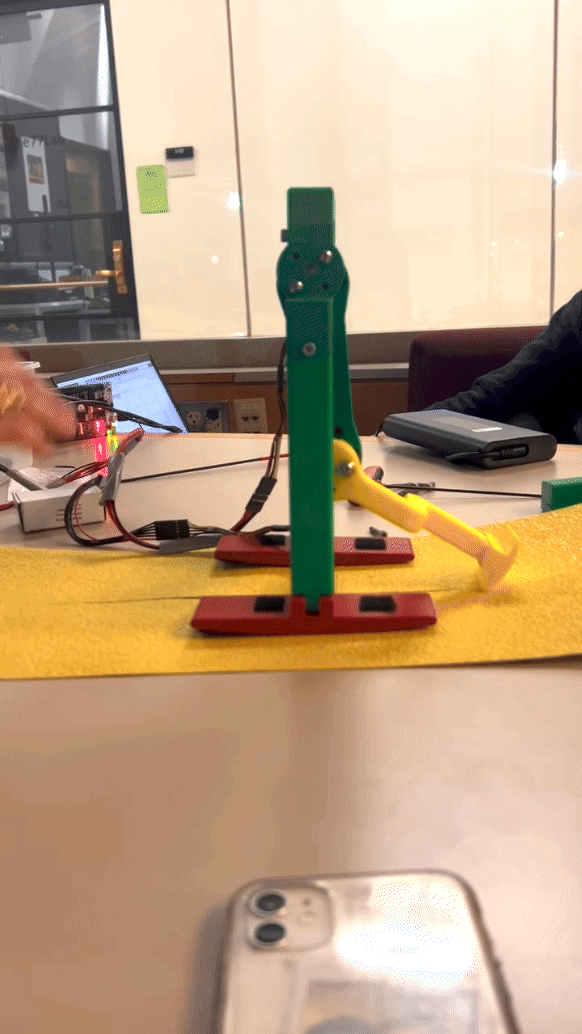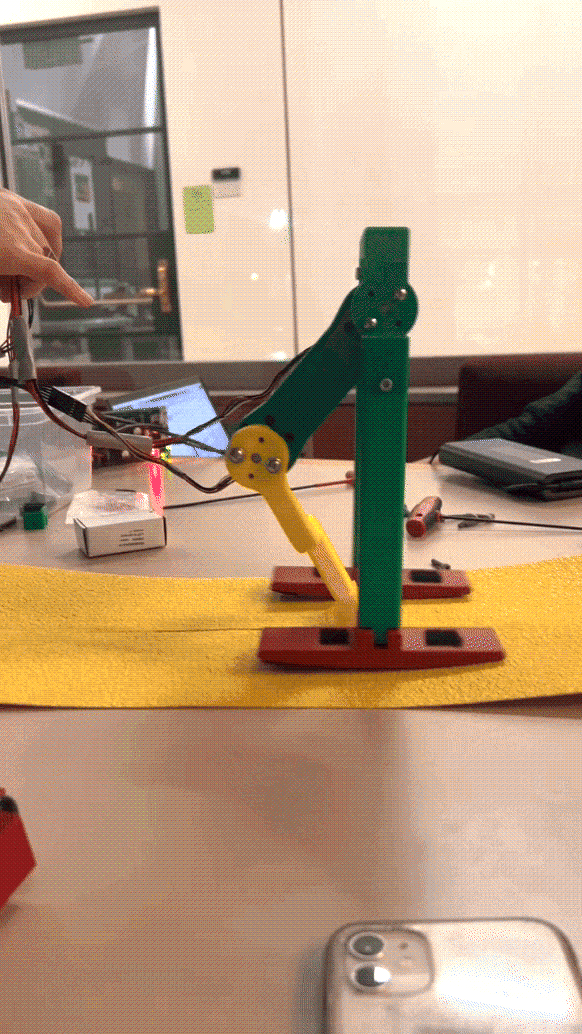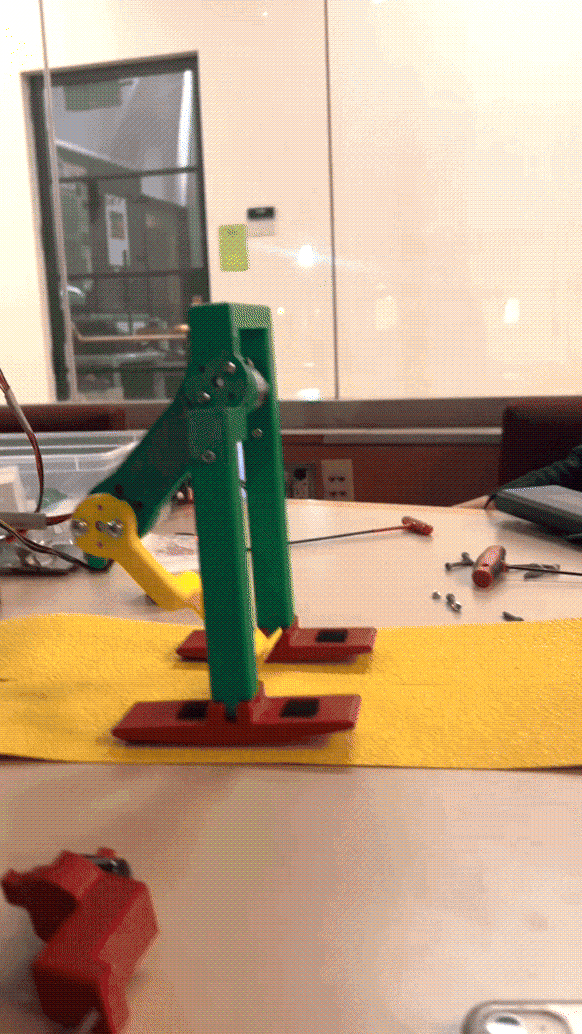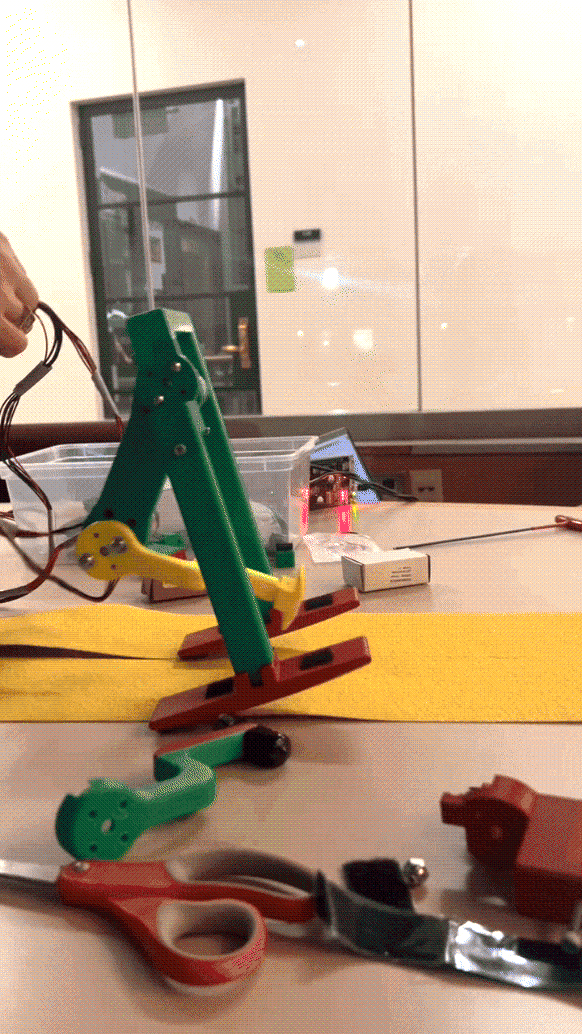
Final motion
Developed a bio-inspired robotic system to investigate the mechanics and efficiency of crutch-assisted walking. I helped formulate the dynamic model and generalized coordinates and set up the model used for trajectory optimization, then focused on the design, fabrication, and integration of the physical robot and support system. The completed platform was used to investigate how gait parameters such as step length, speed, and crutch geometry affect locomotion and cost of transport.
Analysis & Results
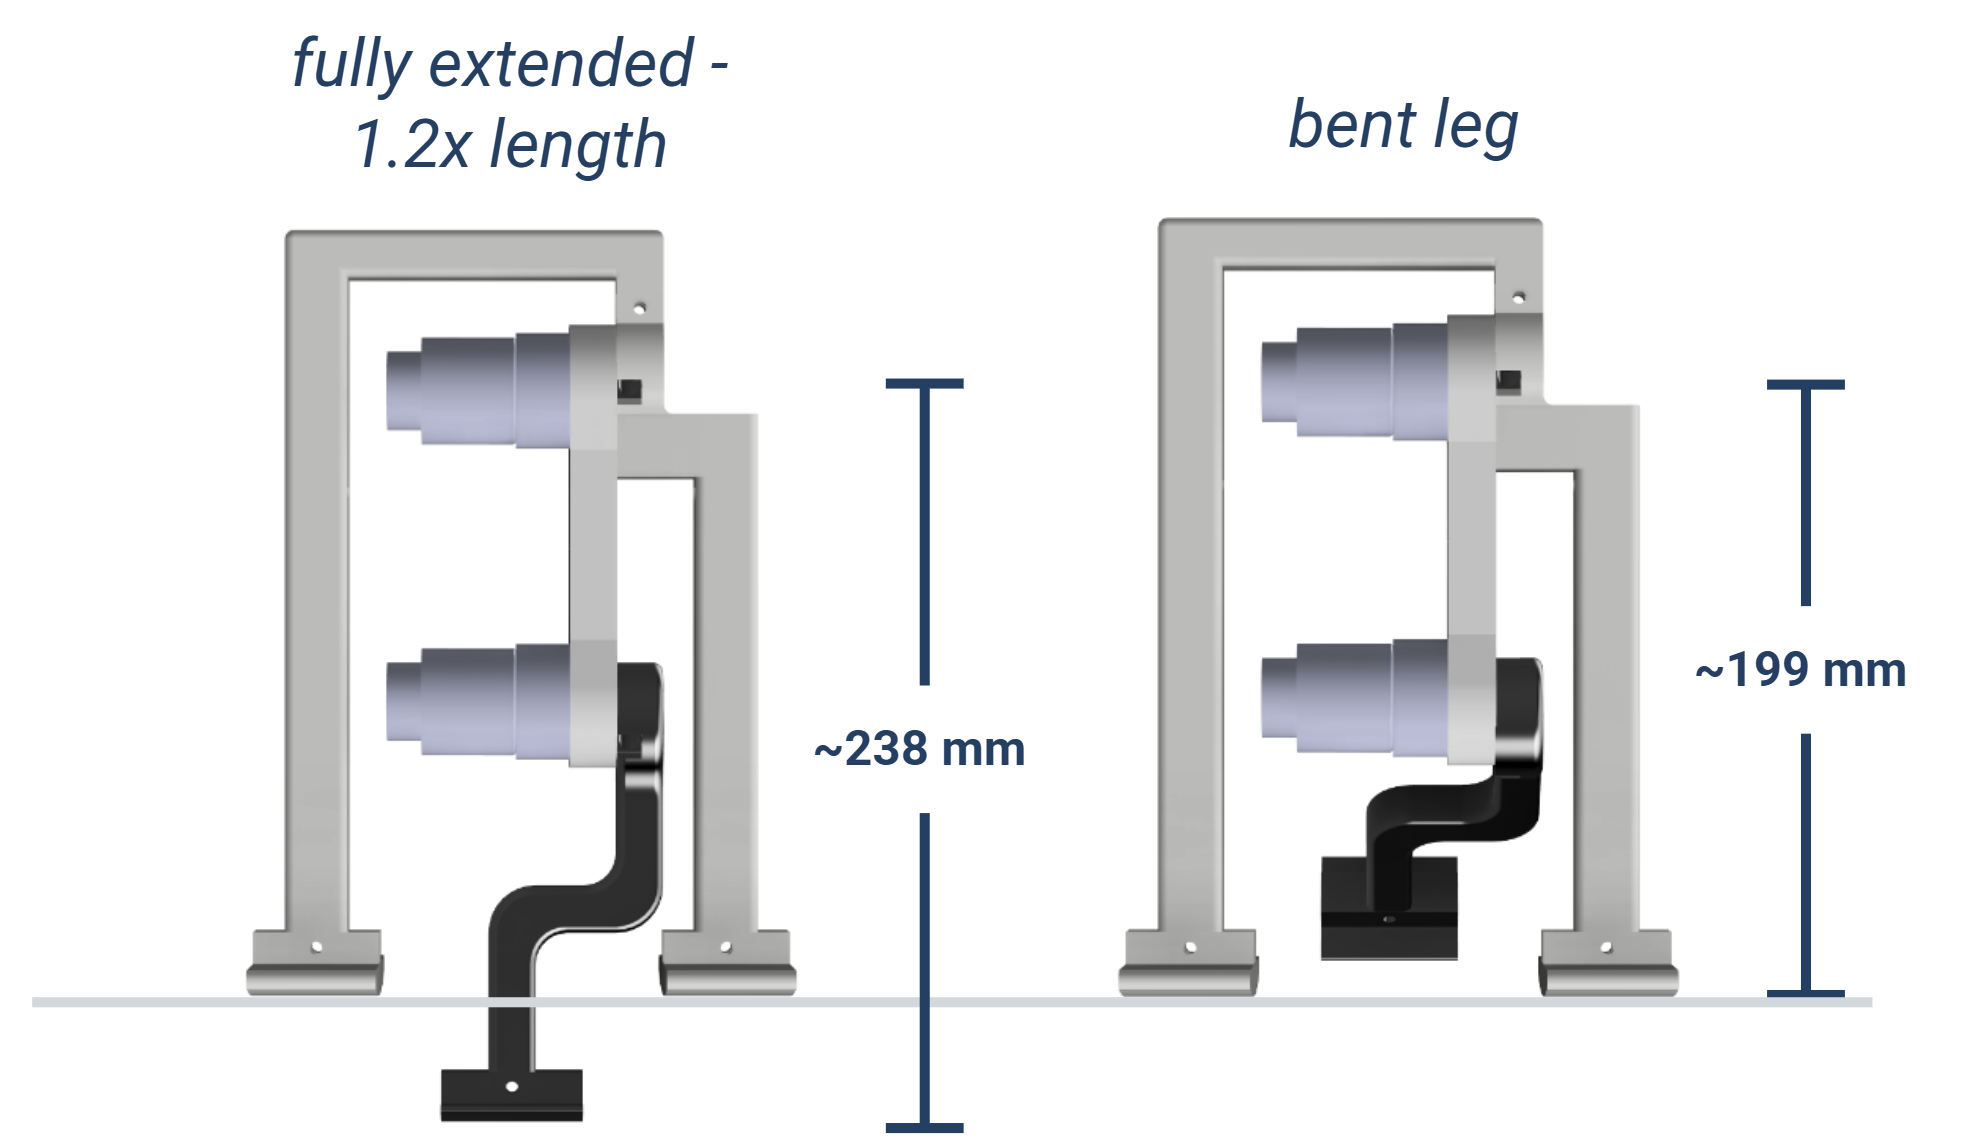
Articulated Leg Mechanism
Designed the articulated leg mechanism to extend during push-off phase and flex during the swing phase, reproducing the leg motion required for the robot’s crutch-assisted gait.
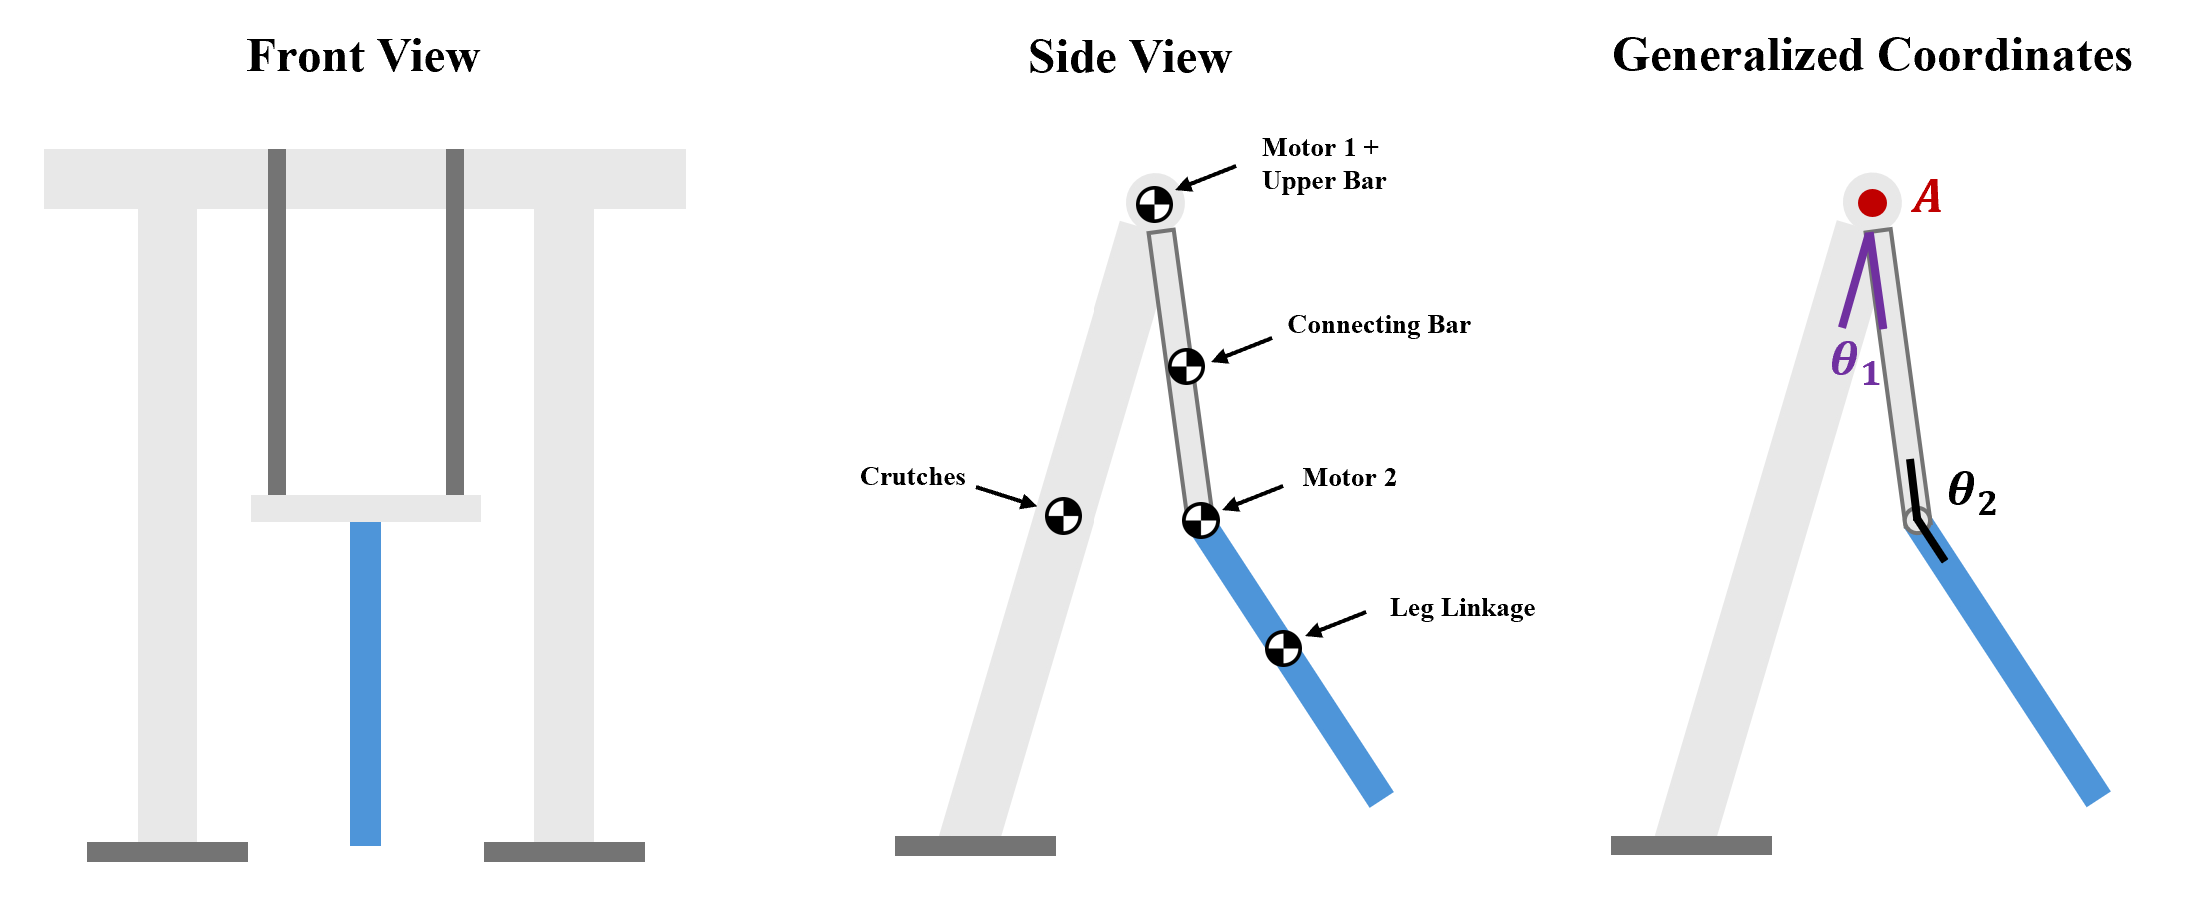
Dynamic Model Formulation
Translated the physical robot architecture into a simplified dynamic model, identifying key components and defining generalized coordinates used to represent system motion and support trajectory optimization.
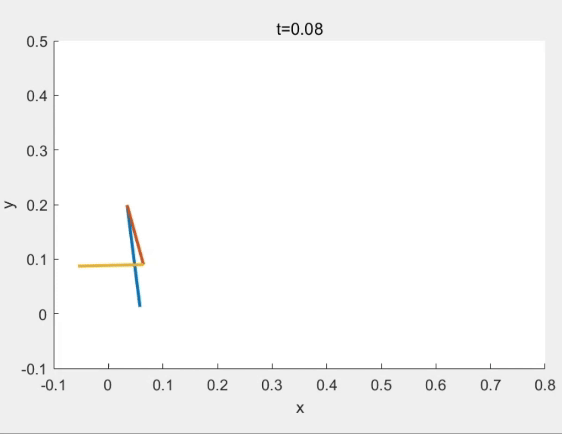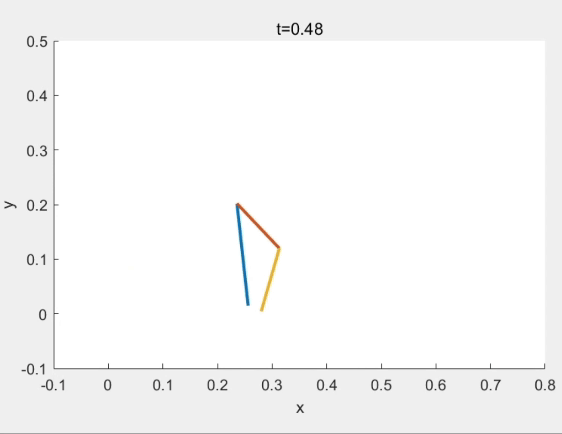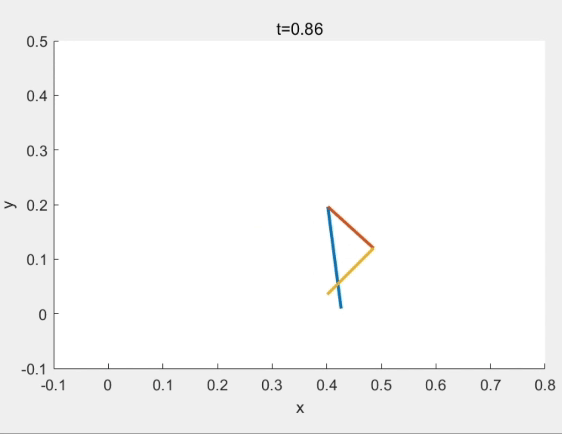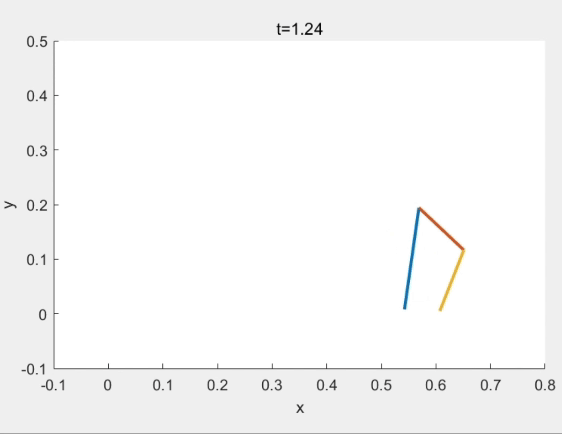
Dynamic Modeling & Simulation
Developed a simplified dynamic representation of the crutch mechanism, defining generalized coordinates and system parameters used to model motion and support trajectory optimization.