Underactuated Robotic Hand
— Robotics · Mechanical Design · Additive Manufacturing —
Summer 2024
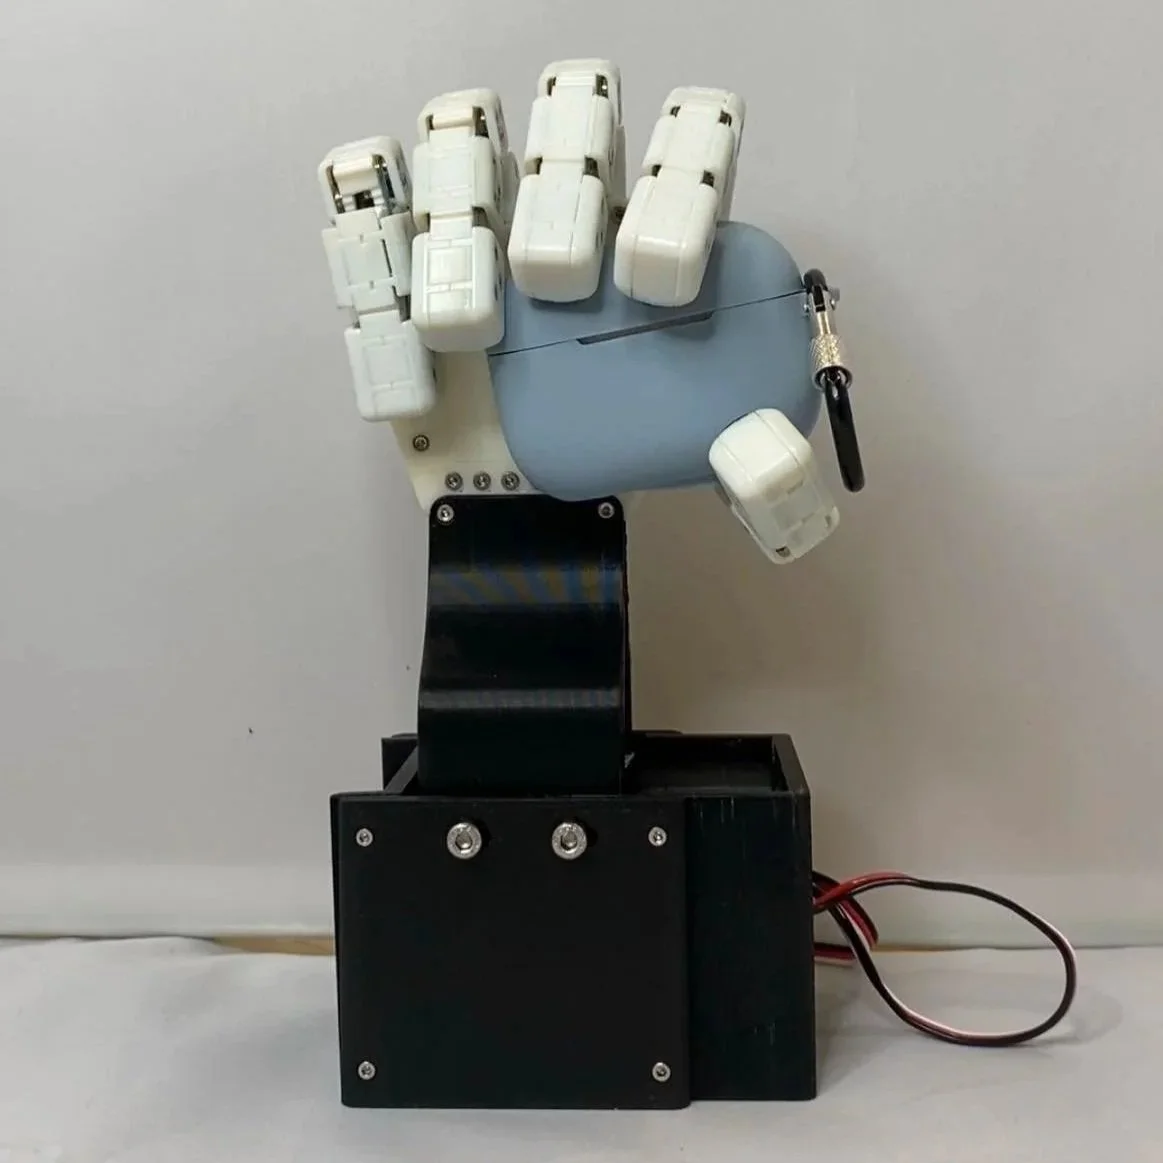
Final Hand Design
Additional Project Photos:
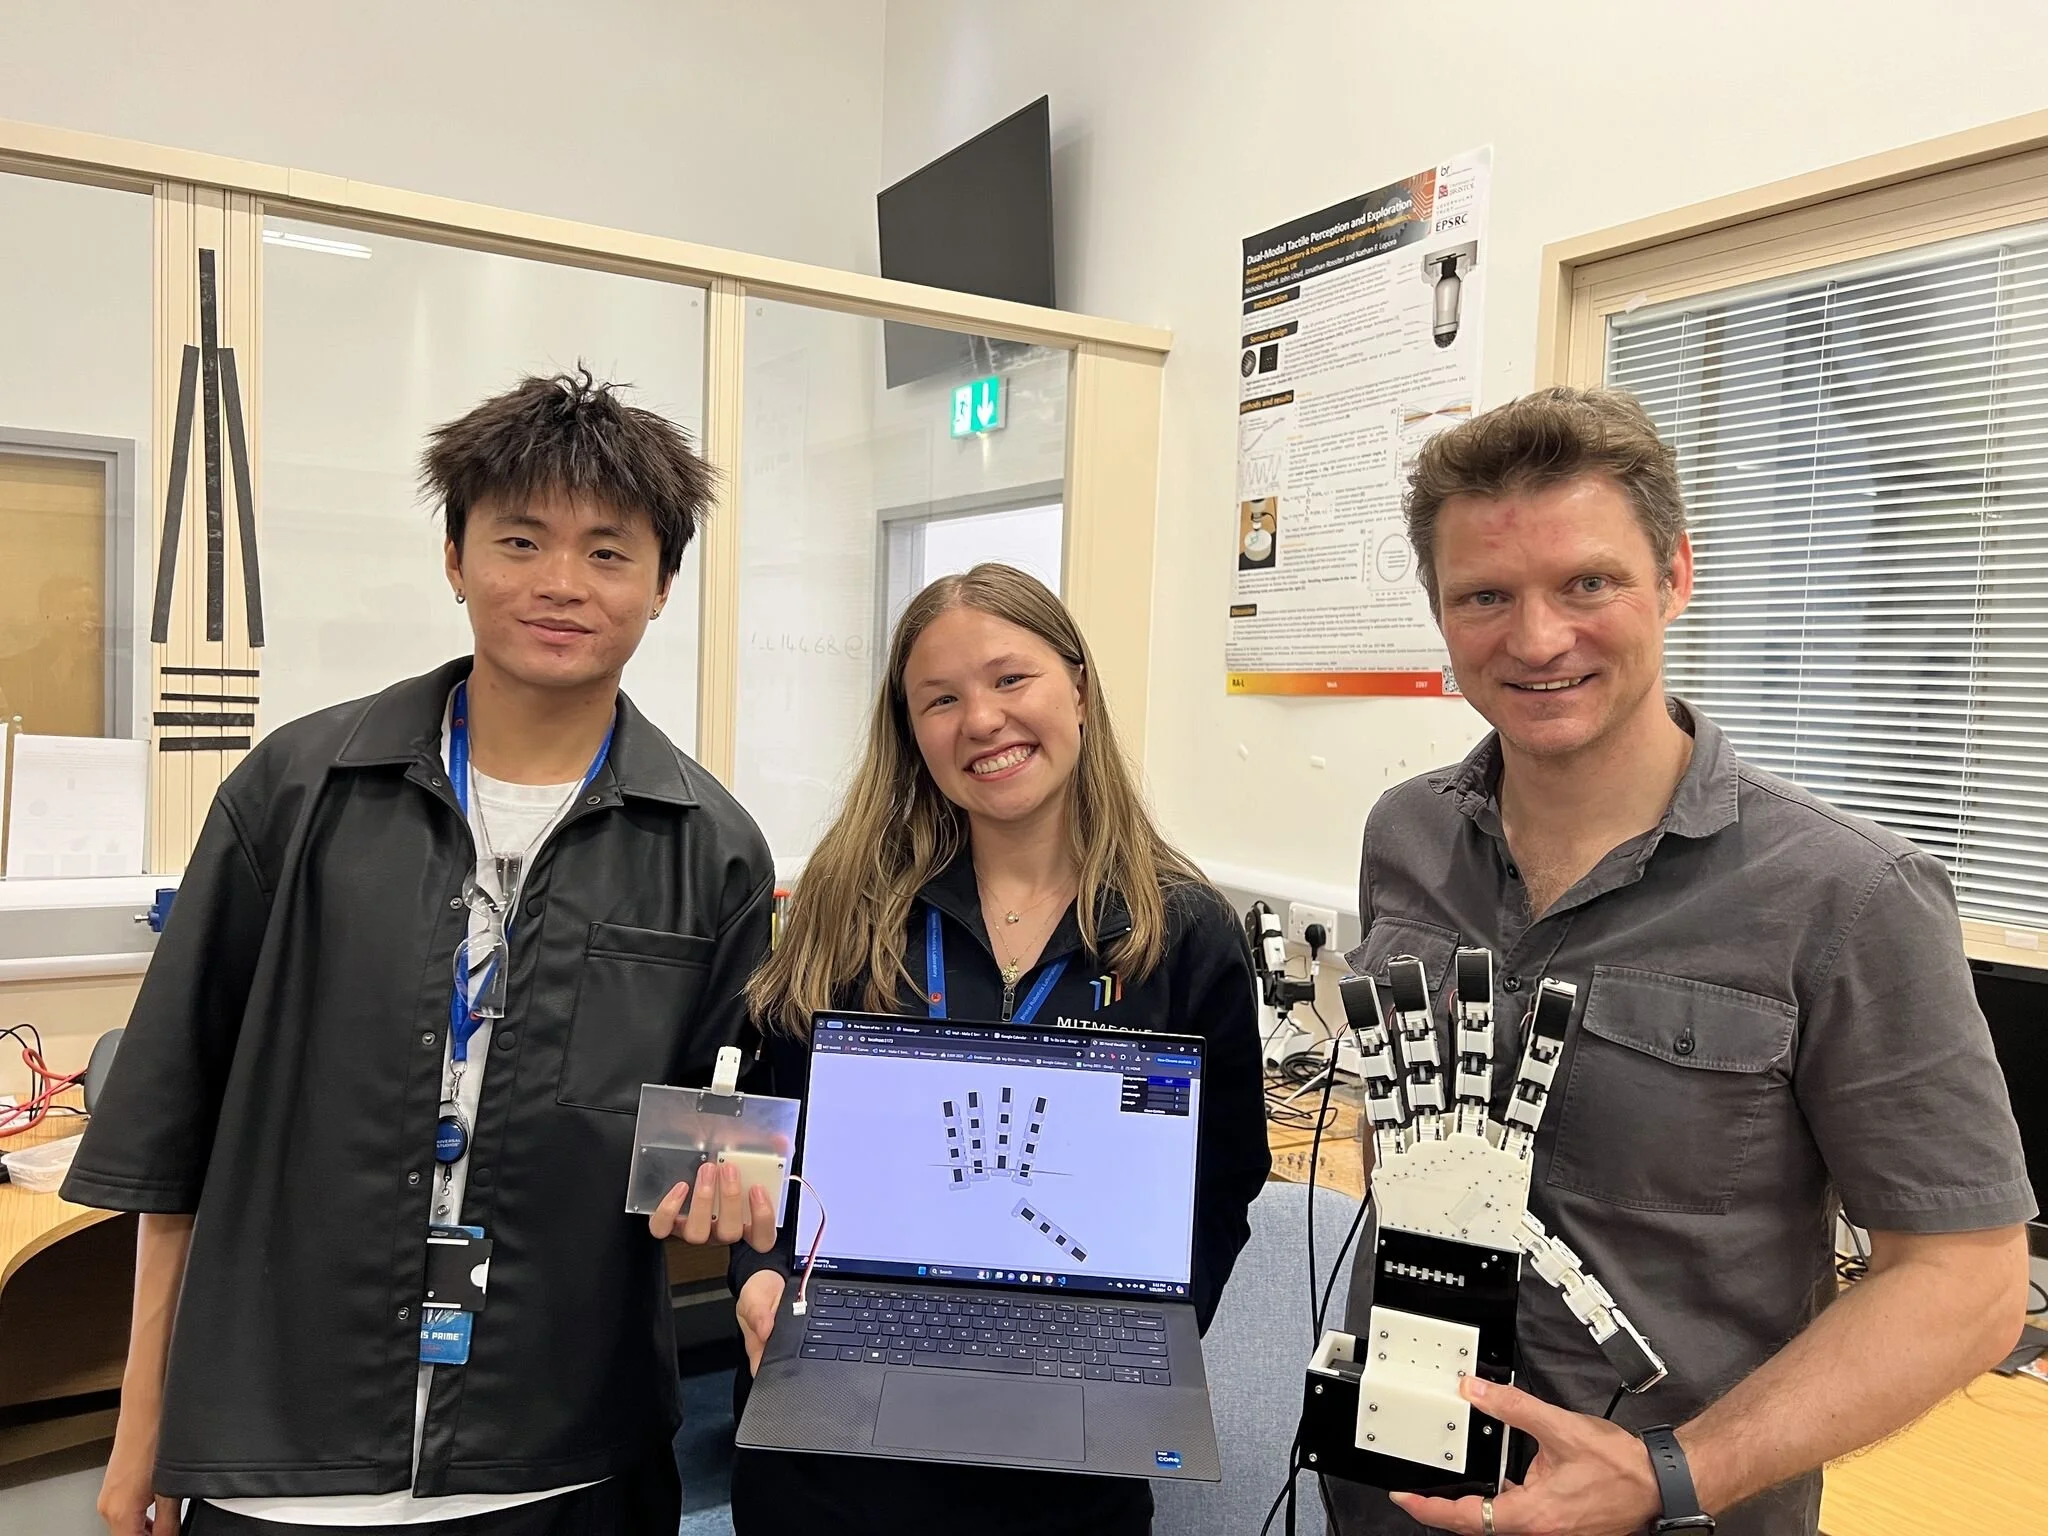
Project team with the original robotic hand and components of the redesigned hand.
Hand Visualization
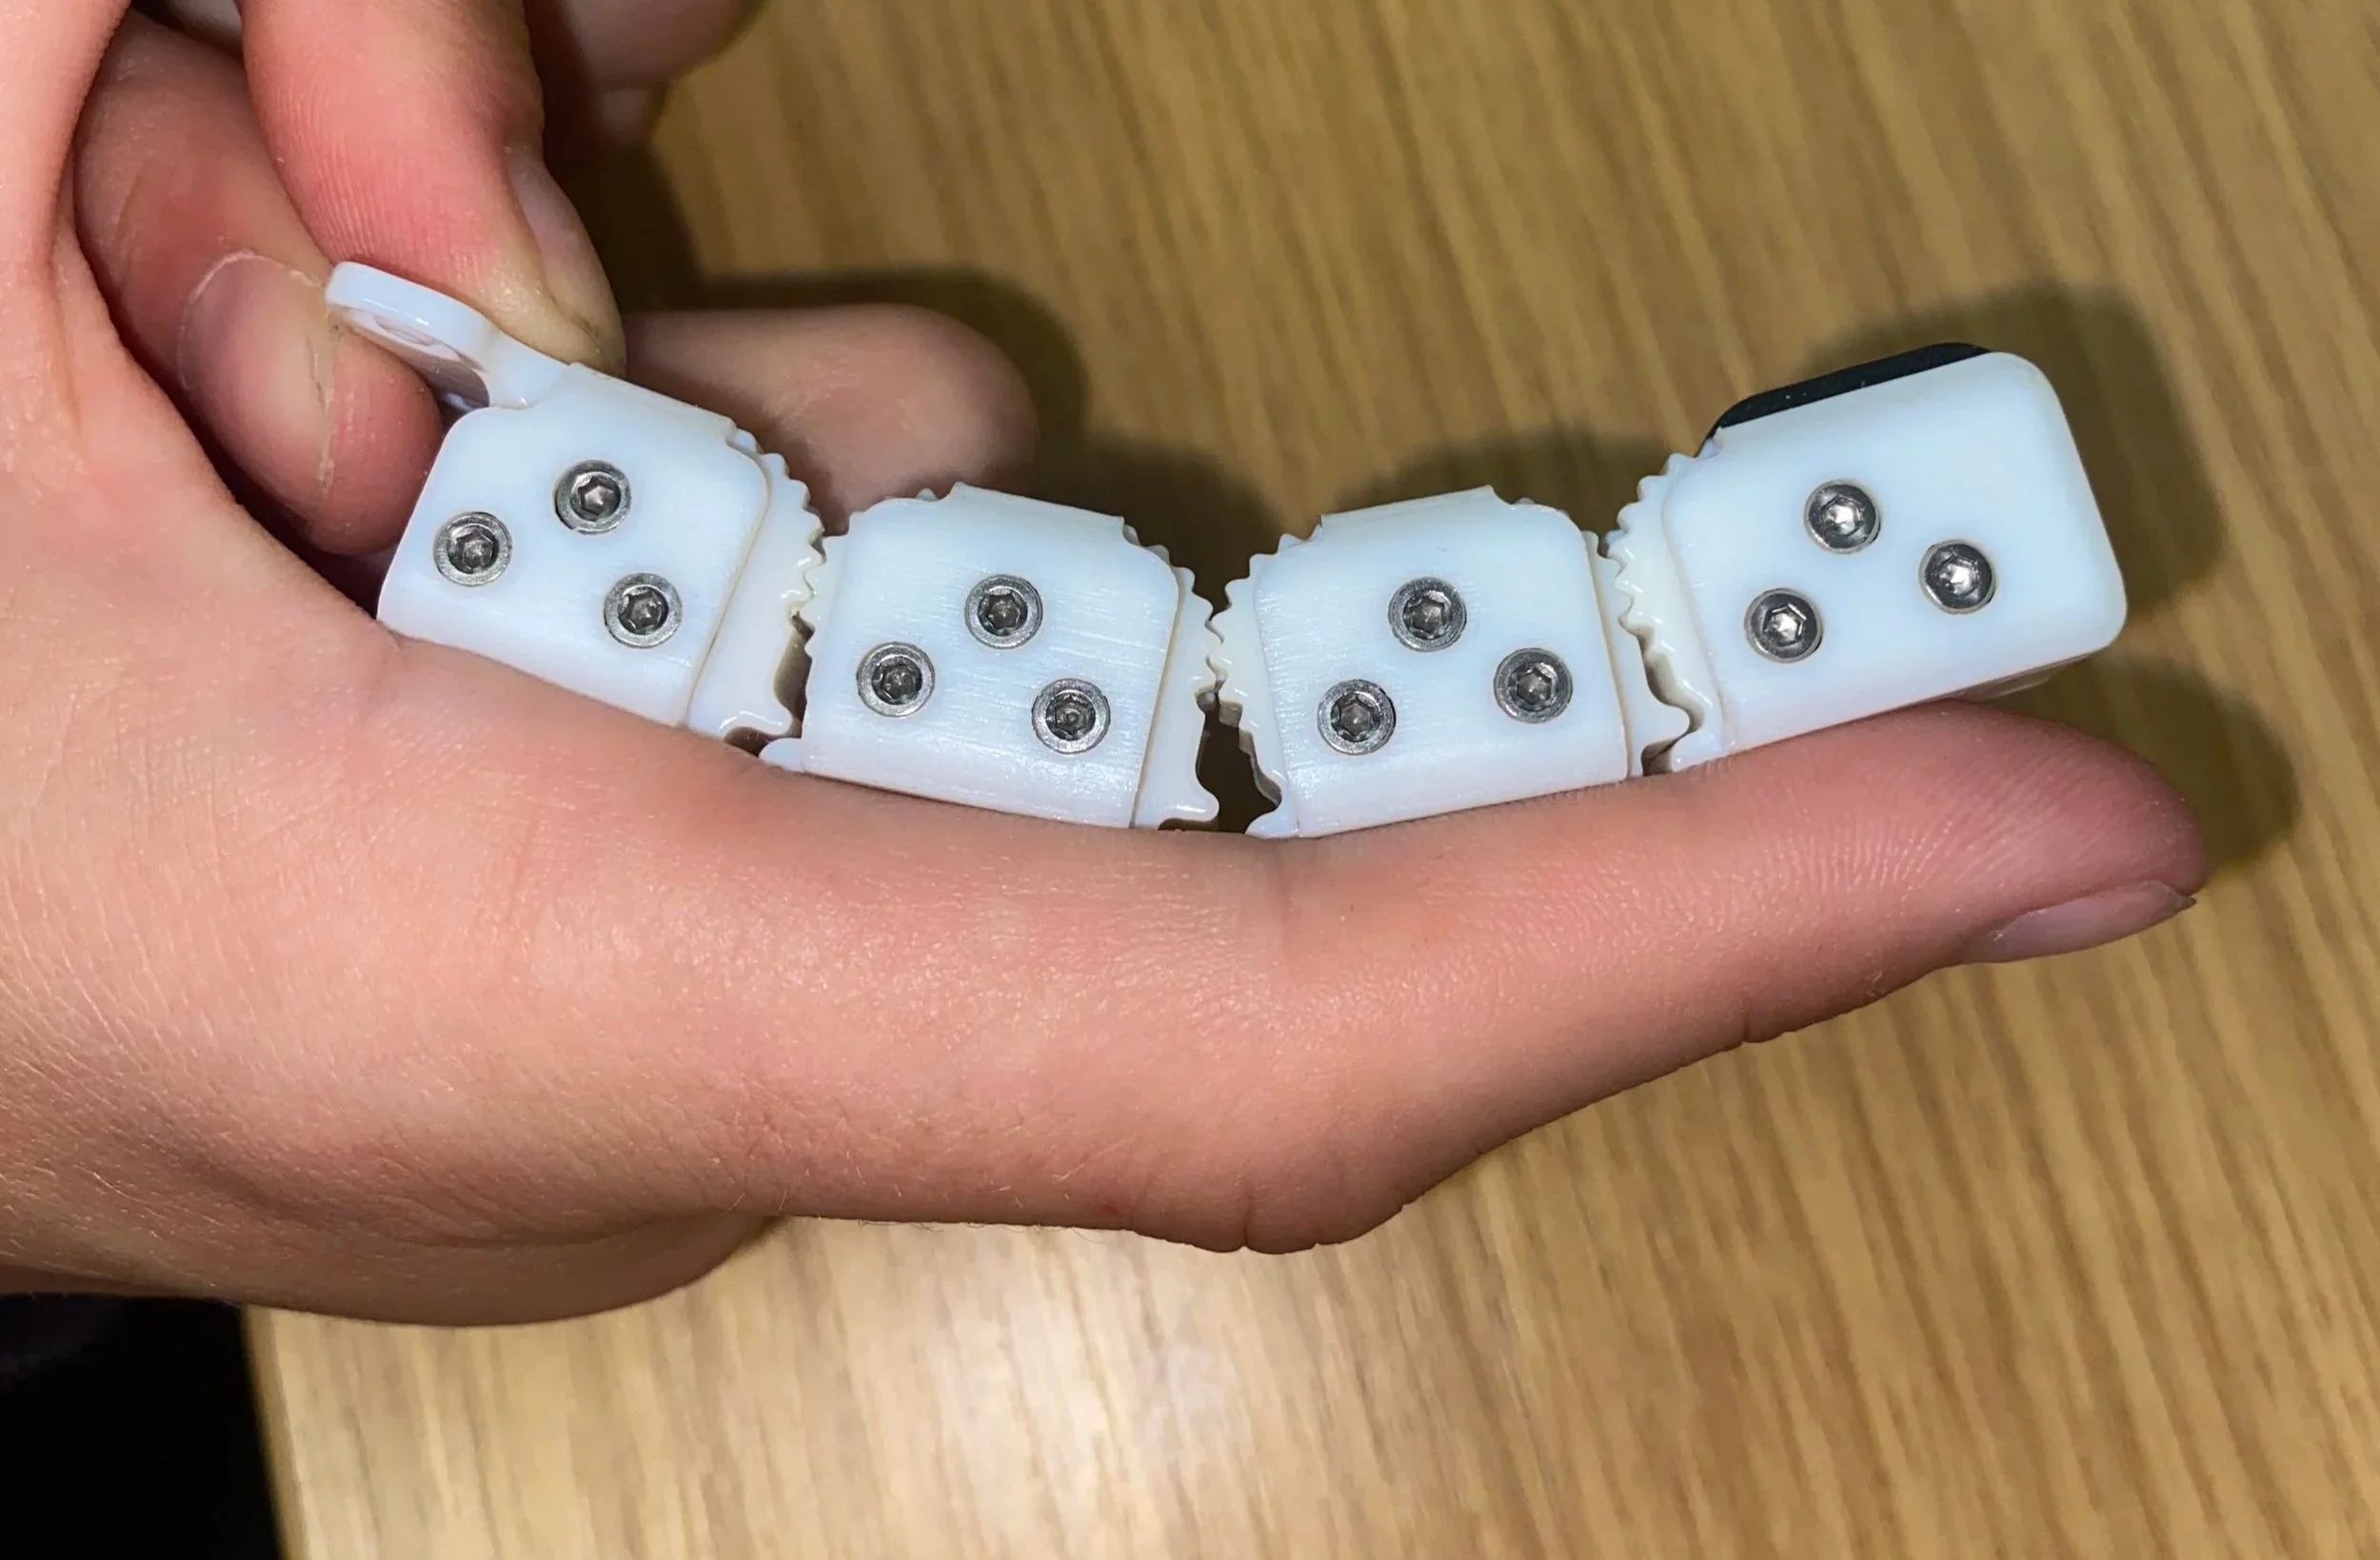
Redesigned robotic finger prototype shown alongside a human finger for scale.
During a 10-week research appointment at the Bristol Robotics Laboratory, I redesigned and built a compact, underactuated robotic hand with integrated magnetic proprioception. I led the mechanical redesign, including the hand geometry, tendon routing, multimaterial 3D-printed components, and integration of magnetic sensing hardware, and developed a digital visualization of the hand's motion.
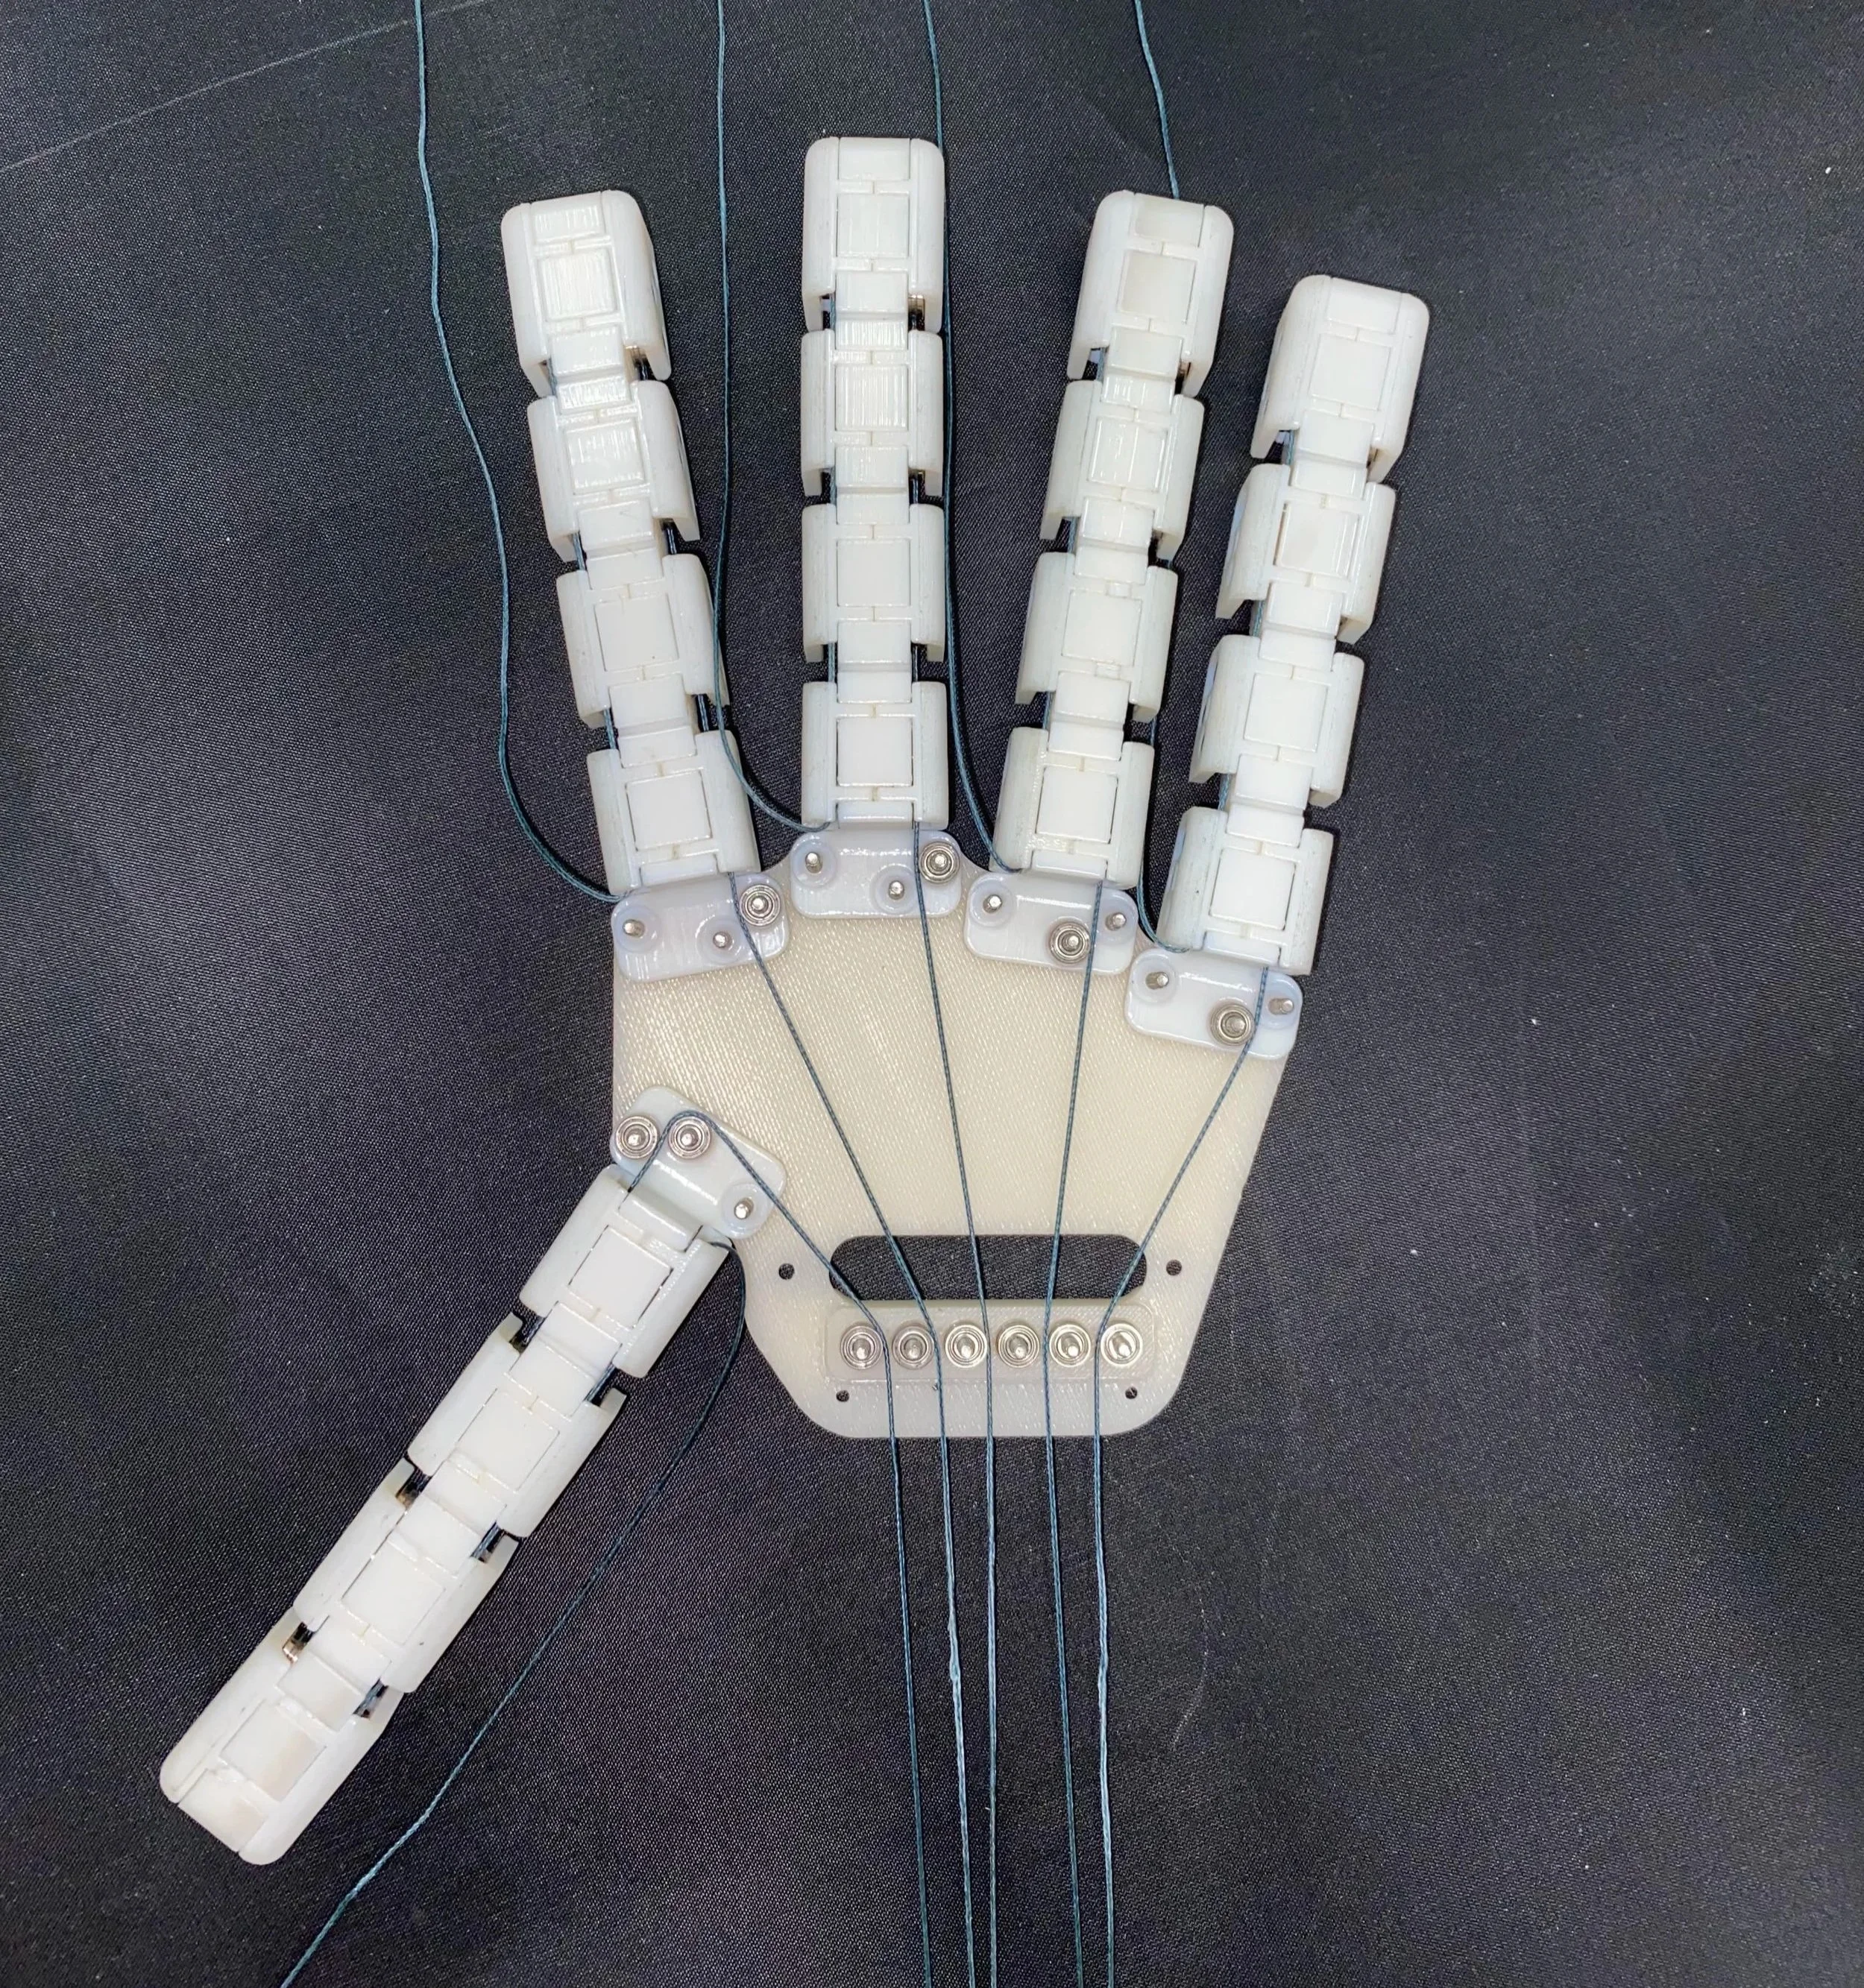
Interior view of the redesigned robotic hand showing tendon routing through the palm.